Skip to content

Revolutionary Collaborative Robot (Cobot) for Pharmaceutical Tank Cleaning

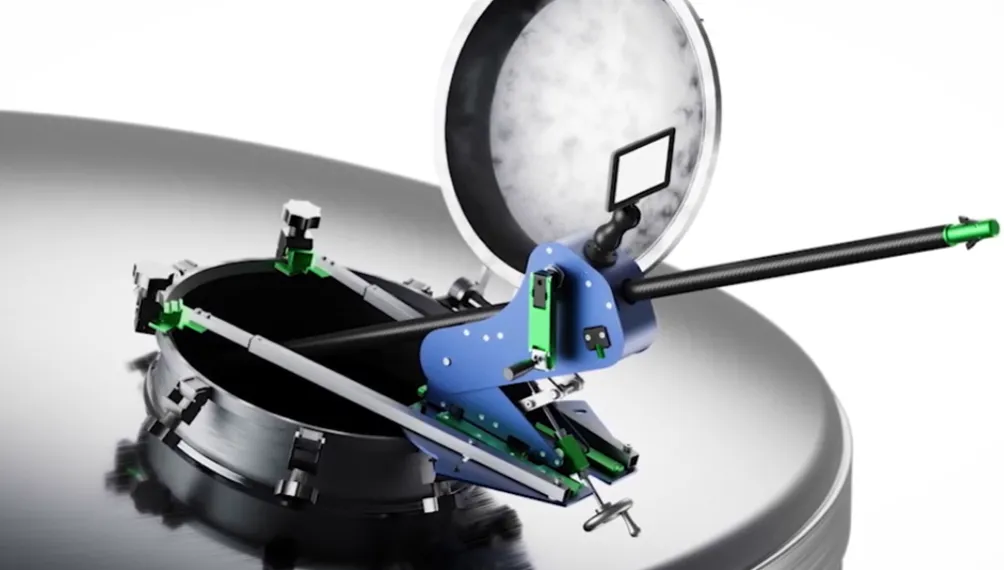
Render of the Swabbot cobot mounted on an open tank manway

An Inside Glimpse Into the Product Development of the Swabbot Collaborative Robot

Swabbot Concept Inside large tank

Product Design Requirements

Rick Mineo, CEO of Swabbot, approached Design 1st with an innovative yet preliminary SwabBot prototype, seeking to refine and scale it for rigorous industrial applications. Design 1st focused on evolving the concept into a compact, autonomous collaborative robot (cobot) capable of executing precise cleaning validations in large confined spaces, enhancing safety and operational efficiency. Key product design requirements included:

  • Reduce Swabbot's size. No final metric was originally understood, other than we needed to get the robot to reach 30’ away and get through the industrial chemical process tanks opening.
  • Enhance the cobot's ability to navigate and swab complex tank interiors.
  • Automate swabbing pressure control. Implement precision mechanics to apply consistent pressure, achieving high percentage contaminant recovery and match or improve upon a human’s consistency.
  • Create simple controls, keeping the UI simple to start with, helping us get the robot into tanks early, and test with real users.
  • Using the right materials in the right places. We integrated carbon fiber in key structural areas, and used aircraft grade metals materials in the structure, with light weight plastics and rubbers in the housings and contact surfaces.
  • Develop the cobot to complete a swabbing cycle within 1-2 minutes, reducing overall cleaning time by 35% compared to manual methods.
Wood Tank Prototype for Final Product Testing

Engineering Challenges

The evolution of the Swabbot into an efficient cobot required overcoming significant engineering challenges to meet the rigorous demands of industrial cleaning applications. Design 1st tackled issues related to size, automation, and operational safety, critical for the cobot’s success. Engineering challenges and solutions included:

  • Reaching 30 feet and applying a consistent force inside a complex geometry led to creating a wooden tank mock-up to ensure the access and accurate function within real tank dimensions.
  • Enhanced the user's ability to sense the robot in place on the wall, with refined sensors to enhance precision and ease of placing the robot on the surface to be swabbed whether it is right-side up, up-side down, curved, flat or vertical.
  • Implemented a robust mechanical fail-safe system to prevent operational errors and protect the cobot and environment during swabbing.
  • Redesigned the user interface to reduce training time significantly and streamline adoption for operators.
Swabbot Launch at ISPE CASA Tech Show in Raleigh

Product Results

Following extensive testing and development by Design 1st, Swabbot stands out as an innovative solution ready to transform industry standards in cleaning validation. Swabbot is now demonstrating the product at various tradeshows. Key product results include:

  • Resulted in more consistent and higher contaminant recovery than human swabbing.
  • Significantly reduced the need for operator training by 40%, lowering labor costs.
  • Creating a safer workplace by significantly reducing the need for humans to enter the confined tank spaces.
  • Successful pre-production prototype ISPE-CaSA Tech Show

Taking a Cobot from initial concept through to final product testing

The initial catalyst to bring in Design 1st was to get a company who covers all of our needs from electrical, mechanical, software, and manufacturing in one group. Design 1st taken us from that early stage now to getting our final prototype and final prototype testing.”
Richard Minoe CEO, Swabbot Solutions LLC